■書誌情報
Yanzhou Jin, Fei Suo, Chang Liu, Yasuhisa Hasegawa, Liming Chen, Yusuke Iwasawa, Yutaka Matsuo, Yaonan Zhu*: Reinforcement Learning Based Multi-Terrain Adaptive Whole-Body Control for a Quadruped Manipulator, IEEE Transactions on Industrial Electronics (TIE), 2026 (*corresponding author)
■概要
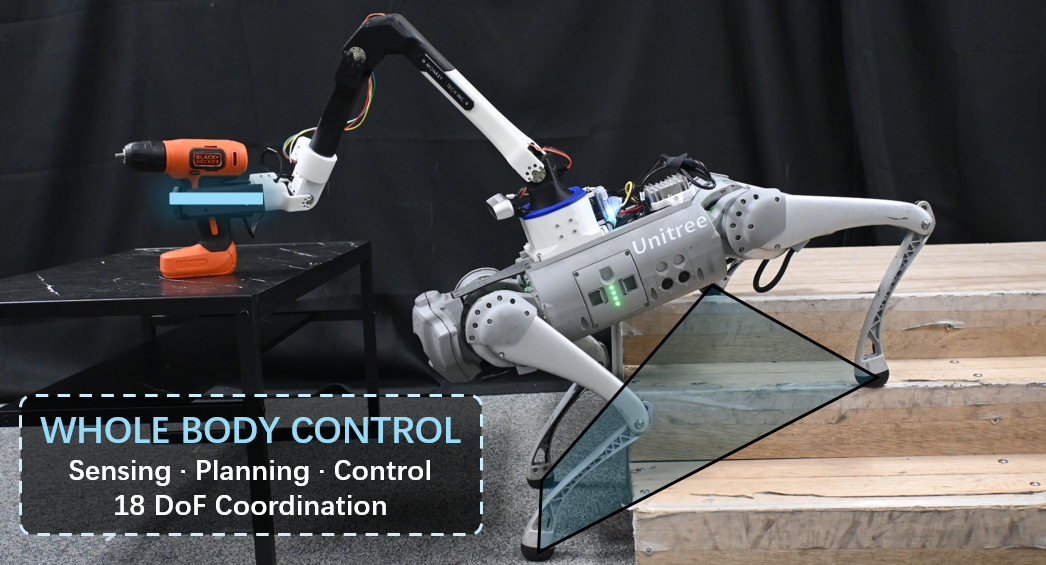
Legged robots equipped with manipulators have the potential to perform loco-manipulation tasks in unstructured environments. However, maintaining task-consistent end-effector behavior during locomotion remains challenging due to terrain-induced disturbances and the strong coupling between locomotion and manipulation, particularly on small-scale quadruped platforms. This paper proposes a reinforcement-learning-based whole-body control framework for quadruped loco-manipulation across complex terrains. The framework integrates a hybrid task representation with task-prioritized whole-body learning to coordinate locomotion and manipulation while maintaining task-consistent end-effector behavior. A lightweight quadruped manipulator platform is also developed for real-world validation. Experiments demonstrate successful deployment on challenging terrains, including slopes up to 30 degrees, stairs, and deformable terrain. These results establish the feasibility of learned whole-body control for small-scale quadruped manipulators and demonstrate the effectiveness of task-prioritized coordination for terrain-adaptive loco-manipulation.